Robotics
Trail Mix: Multi-Robot Coordination
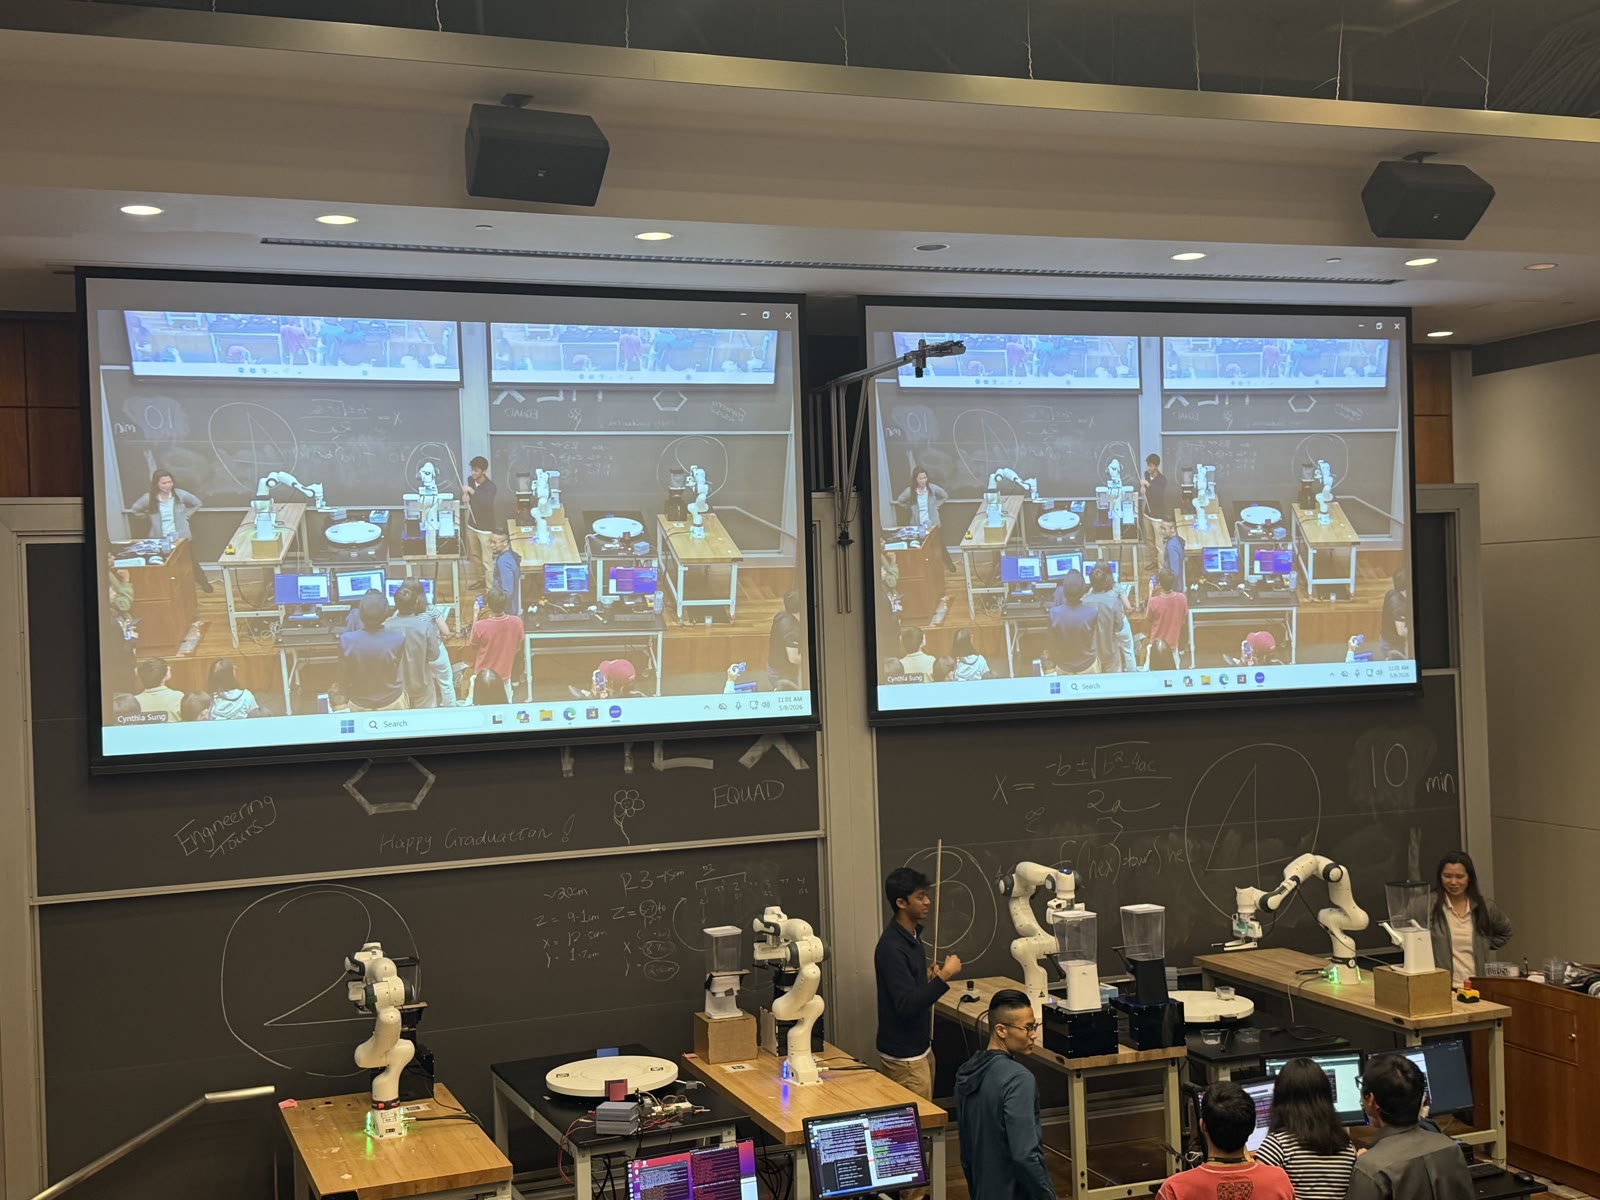
The project aims to coordinate four robots across two assembly lines to prepare and serve custom trail mix orders. The system connects customer orders, task scheduling, perception, and robot control so robots can pick up cups, dispense ingredients, exchange cups at turntables, mix, and serve the finished orders.
Shared communication layer
I led the ROS communication layer that lets these components work together. Custom message definitions and a shared Python interface, TrailMixInterface, give teams a consistent way to exchange commands, world state, and execution feedback. Message validation and publish-rate monitoring help catch integration errors, while status and failure messages let the scheduler track progress and respond when tasks fail.
Demo
Robots operating at the ingredient and cup-handling stations.